Nishi Family › Compare › Heavy-Appliance Mobility
Nishi Compare · capabilities, evidence and delivery
Heavy-Appliance Mobility
Compare capabilities and delivery evidence. Source discovery, qualification, deployment and accepted outcomes are separate; an open contract names work still to verify.
Nishi glide-base plus stair-module appliance mover (designed from the first bit up) vs Airsled air film and Escalera StairCat and PowerMate motorized climbers and tracked crawler dollies -- Aug-2026 field
Overview
The purpose, declared position and evidence coverage of this domain. Source presence and completed acceptance are different measures.
Where we are. MEASURED 2026-08-19: no Nishi hardware exists in this domain. What IS measured in tree: the product decomposer (pd_parse), the sovereign STL-to-G-code slicer (printed fixtures), the landed-cost corridor engine (lc_calc) and the sourcing-mix reshore pricer (sp_mix) -- the design-to-business substrate every physical product inherits. The Aug-2026 field is mapped and mirrored: air film for floors, dealer-priced motorized climbers at 1200 to 1,500 lb, consumer tracked crawlers in the 330 lb class.
Where we need to go. OPERATOR ASK (2026-08-19): easy-glide wheels for heavy appliances that can even go up stairs. The wedge no incumbent spans: a PERMANENT under-appliance glide base that mates with a detachable stair-climb module. Ship the design organs first and prove them by gates, steel second -- the physics and costing organs are reusable across every physical product that follows.
Research bar. PowerMate automatic braking, the field safety bar is measured on operator-release lock behaviour documented across the powered-climber field. Theirs: the load locks in place the instant the operator releases the controls [powermate]. Ours: our AM4 contract adopts lock-on-release as a REFUSAL rule -- a design that cannot lock does not pass its gate.
Business case
| Axis | Position | Figures | Decision |
|---|---|---|---|
| Investment | The design-engine leg is pure organ work on the existing substrate; hardware spend begins at one consumer crawler teardown unit in the 330 lb class [crawler] plus printed fixtures | estimated 10 u to a field-proven article; cash before steel is bounded by the teardown unit and fixture stock | fund the organ leg now, gate hardware spend on the M1 BOM verdict |
| Market | Three incumbent formats and none spans the ask: air film for finished floors [airsled], dealer-channel motorized climbers at 1200 to 1,500 lb [escalera] [powermate] [liftkar], consumer tracked crawlers [crawler] | the permanent glide base plus stair module covers a gap no format serves | position retrofit-first: the base addresses every appliance owner, the module addresses movers and property managers |
| Opportunity cost | The same 10 u could extend an existing revenue lane; the offset is that AM1-AM5 are reusable physics and costing organs every later physical product inherits | the first product pays the substrate tax for the whole physical lane | charge the substrate to the physical-products program, not to this product alone |
| Go to market | Movers, appliance dealers and property managers buy outcomes, not tools; the incumbent climbers sell through dealers and rentals [liftkar] | house-call service pricing per move is the proven channel shape | start with the service wedge to fund the product wedge; the GTM facade ranks channels once cotton-style channel rows are admitted |
| Buy vs build | Air film, powered climbers and crawlers are mature BUYS for internal moving needs today [airsled] [powermate] | nothing on the market is a permanent under-appliance base with a stair module | buy one crawler for teardown reference; build only the wedge |
Latest recorded release
No valid dated release entry is recorded for this domain.
Release entries describe recorded changes; they do not establish that every capability passed evaluation.
7 of 15 capability source symbols found|2 of them authored stronger-claims|8 open|coverage 466/1000|adoption 3 full / 4 partial
Evidence profile — what the gaps on this board actually are
Measured by nx_swcompare_evidence, read back by nx_evprofile_lib. Every figure is a count with its denominator — there is deliberately no score, no grade and no percentage anywhere in this band, because a stored scalar is a field a seat can edit and a counted partition is not.
evidence|grounded 7/7|unsupported 0|gates green 0/0|proven able to fail n/a — no gate ran|green at 0/0 0|open gaps 8|of them unnamed 0|of them proof withheld 0|flips ready 0
proven able to fail counts the gates that have a RECORDED RED — nx_gate_bite mutated the gate subject, rebuilt it, watched the gate go red, and that record is inside the shared TTL. never bitten is its complement over the same denominator: those gates ran and were green, and nothing has ever shown them able to detect anything, so their green is a statement about this run and not about the gate. green at 0/0 is a separate and much weaker observation — the gate printed GREEN on a zero denominator, so its own tooth counter says it examined nothing. A gate can be green, non-zero, and still never bitten; that is the common case and it is now visible instead of implied.
partition: grounded + unsupported = 7 vs present 7 · named + unnamed + withheld = 8 vs open 8 · both reconcile
liar-kill conj=GPqN · first failing conjunct: quorum
graded document: BUILDROOT tree, 7137 bytes · gates map: NONE · stamped 36d 23h ago · STALE against the shared TTL of 604800s — this is evidence about a build nobody can vouch for now · source ../knowledge/status/evstamp_appliancemove.verdict
| Gap class | What it is, and the work it names |
|---|---|
| CLAIM-ONLY | No declared gate ran for this board, so every capability mark here rests on a symbol existing in source and on nothing executing. The remedy is to WRITE a .gates map naming gates that already run — authoring, not research. |
| STALE | This profile is older than the shared TTL, or its clock ran backwards. It is reported as unusable rather than as fresh, because being wrong in the direction of refusing is the safe direction. |
nx_swcompare_evidence appliancemove itself and are not carried on the stamp, so this page names the classes and the producer names the rows. That split is stated rather than hidden: a count without a worklist is not actionable, and this band is honest about which half of that it is.Production map
Follow the dependencies, declared acceptance criteria and recorded priorities. Inspect source binding before treating a rank as executable work.
Ranking source binding: PLAN_MATRIX_BOUND_ONLY. Recorded priorities require current acceptance evidence and resource checks before execution.
Ranking matches the captured plan and matrix only. Latest execution outcome, research freshness, accepted delivery and investment return are unverified.
Recorded priority estimates
Order from nx_compare_rank (nx_dr_ocm: (deficit + cost-of-delay + option + enables) x sponsor x self-sufficiency x momentum / cost). FINISH rows are rungs whose symbol is present but whose organ is short of full adoption: listed before new work by this heuristic. Priority is not measured delivery cost or execution readiness. Stamp: # asof=1790081913 domain=appliancemove target_version=0.1 rungs=7 done=0 open=7 finish=0 ranker=nx_dr_ocm
| # | Stage | Rung | Priority | Derivation |
|---|---|---|---|---|
| #1 | 0.1 | Stair-geometry envelope solver (AM1) am_stair_geom dossier | 2000 | v=20 m=1 c=10 |
| #2 | 0.1 | Load and margin calculator (AM2) am_load_margin dossier | 2000 | v=20 m=1 c=10 |
| #3 | 0.1 | CG tipover simulator (AM3) am_tipover_sim dossier | 1000 | v=10 m=1 c=10 |
| #4 | 0.1 | Descent brake-energy model and lock spec (AM4) am_brake_energy dossier | 1000 | v=10 m=1 c=10 |
| #5 | later | Glide-base design pack (AM6) am_glide_base dossier | 1000 | v=20 m=1 c=20 |
| #6 | later | Field-trial gate (AM7) am_field_gate dossier | 200 | v=4 m=1 c=20 |
| #7 | later | BOM, landed cost and sourcing verdict (AM5) am_bom_cost dossier | 0 | v=0 m=1 c=20 |
Declared roadmap — contract, acceptance, executor, effort
| Rung | Closes with | Definition of done (pre-declared) | Executor | Est. |
|---|---|---|---|---|
| Stair-geometry envelope solver (AM1) | am_stair_geom | OSHA 1910.25 riser and tread envelope as DATA rows [oshastairs]; solver derives module geometry; gate includes a neg-control stair outside the envelope that must REFUSE | Organ | 1 u |
| Load and margin calculator (AM2) | am_load_margin | BOM-derived axle, bearing and deck margins; gate refuses any margin under the declared floor; capacities graded beside the 1200 and 1,500 lb incumbents [escalera] [powermate] | Organ | 1 u |
| CG tipover simulator (AM3) after AM1 | am_tipover_sim | stair rake and load-height sweep; neg-control fixture MUST tip; verdict carries the margin number, never a bare pass | Organ | 1 u |
| Descent brake-energy model and lock spec (AM4) after AM2 | am_brake_energy | worst-case descent energy vs brake rating with lock-on-release as the refusal rule [powermate] | Organ | 1 u |
| BOM, landed cost and sourcing verdict (AM5) after AM2 | am_bom_cost | every component priced through lc_calc corridors and sp_mix reshore path; buy-vs-build table regenerates from the organ output | Organ | 2 u |
| Glide-base design pack (AM6) after AM2 | am_glide_base | floor-pressure model vs flooring classes as DATA graded beside the air-film bar [airsled]; footprint fit rows for common appliances; printed-fixture lane via the slicer | Organ | 2 u |
| Field-trial gate (AM7) after AM3,AM4,AM6 | am_field_gate | declared stair fixtures, measured climbs, descents, aborts and floor inspections; REFUSES on partial coverage | Organ | 2 u |
Milestones
| Milestone | Rungs | Cumulative |
|---|---|---|
| M0 · Design engine proven | AM1,AM2,AM3,AM4 | 4 u |
| M1 · Priced and sourced | AM5 | 6 u |
| M2 · Prototype-ready pack | AM6 | 8 u |
| M3 · Field-proven article | AM7 | 10 u |
| Class | Count | Note |
|---|---|---|
| bars | 0 | sotabar rows on the plan |
| fresh | 0 | the bar month is the current month |
| attested | 0 | an older bar with a this-month barscan reporting no newer entry |
| stale | 0 | a this-month scan saw a newer month the bar ignores |
| unattested | 0 | nobody looked this month |
| malformed | 0 | a sotabar row missing a field |
| duplicate | 0 | bar ids an earlier row already carries |
| bars, summed | 0 | RECONCILED: the parts sum to the total 0 |
| current month | 2026-10 | the month every bar is judged against |
Inspect a rung and its prerequisites
Declared nodes 7. Rank input binding: PLAN_MATRIX_BOUND_ONLY. Dependency order is authored. Implementation, acceptance evidence, authority and resource readiness are unverified. No action is recommended or dispatched here.
Plan SHA-256 3d34cbf7d449fb52c1021c76ee57b7c86817d9423fea5ec1e11d666d08d0555d. Target rows 0; role rows 0. Existing risks and release worklog retain their own scope; no node completion is inferred.
Runtime observation coverage: 0 of 7 rungs have current, identity-bound execution observations. Observation may report RED. Accepted completion remains unknown; source presence, qualification and deployment do not establish it.
Use Enter or Space on a rung to inspect its contract. Prerequisite links locate another rung in this list; open its summary to inspect it. Estimates are authored effort, not forecasts.
AM1 — Stair-geometry envelope solver
Prerequisites: None declared; this does not establish execution eligibility.
Contract:
am_stair_geomAcceptance: OSHA 1910.25 riser and tread envelope as DATA rows [@oshastairs]; solver derives module geometry; gate includes a neg-control stair outside the envelope that must REFUSE
Authored effort: 1. Executor kind: Organ. Responsible, accountable and verifier not established. Inspect retained worklog.
Runtime observation: UNKNOWN; outcome UNKNOWN; observed epoch -1. Declared owner: . Receipt
, SHA-256. Identity-bound observation is not accepted completion. Qualification and deployment remain unverified by this projection.AM2 — Load and margin calculator
Prerequisites: None declared; this does not establish execution eligibility.
Contract:
am_load_marginAcceptance: BOM-derived axle, bearing and deck margins; gate refuses any margin under the declared floor; capacities graded beside the 1200 and 1,500 lb incumbents [@escalera] [@powermate]
Authored effort: 1. Executor kind: Organ. Responsible, accountable and verifier not established. Inspect retained worklog.
Runtime observation: UNKNOWN; outcome UNKNOWN; observed epoch -1. Declared owner: . Receipt
, SHA-256. Identity-bound observation is not accepted completion. Qualification and deployment remain unverified by this projection.AM3 — CG tipover simulator
Prerequisites: AM1 (acceptance unverified)
Contract:
am_tipover_simAcceptance: stair rake and load-height sweep; neg-control fixture MUST tip; verdict carries the margin number, never a bare pass
Authored effort: 1. Executor kind: Organ. Responsible, accountable and verifier not established. Inspect retained worklog.
Runtime observation: UNKNOWN; outcome UNKNOWN; observed epoch -1. Declared owner: . Receipt
, SHA-256. Identity-bound observation is not accepted completion. Qualification and deployment remain unverified by this projection.AM4 — Descent brake-energy model and lock spec
Prerequisites: AM2 (acceptance unverified)
Contract:
am_brake_energyAcceptance: worst-case descent energy vs brake rating with lock-on-release as the refusal rule [@powermate]
Authored effort: 1. Executor kind: Organ. Responsible, accountable and verifier not established. Inspect retained worklog.
Runtime observation: UNKNOWN; outcome UNKNOWN; observed epoch -1. Declared owner: . Receipt
, SHA-256. Identity-bound observation is not accepted completion. Qualification and deployment remain unverified by this projection.AM5 — BOM, landed cost and sourcing verdict
Prerequisites: AM2 (acceptance unverified)
Contract:
am_bom_costAcceptance: every component priced through lc_calc corridors and sp_mix reshore path; buy-vs-build table regenerates from the organ output
Authored effort: 2. Executor kind: Organ. Responsible, accountable and verifier not established. Inspect retained worklog.
Runtime observation: UNKNOWN; outcome UNKNOWN; observed epoch -1. Declared owner: . Receipt
, SHA-256. Identity-bound observation is not accepted completion. Qualification and deployment remain unverified by this projection.AM6 — Glide-base design pack
Prerequisites: AM2 (acceptance unverified)
Contract:
am_glide_baseAcceptance: floor-pressure model vs flooring classes as DATA graded beside the air-film bar [@airsled]; footprint fit rows for common appliances; printed-fixture lane via the slicer
Authored effort: 2. Executor kind: Organ. Responsible, accountable and verifier not established. Inspect retained worklog.
Runtime observation: UNKNOWN; outcome UNKNOWN; observed epoch -1. Declared owner: . Receipt
, SHA-256. Identity-bound observation is not accepted completion. Qualification and deployment remain unverified by this projection.AM7 — Field-trial gate
Prerequisites: AM3 (acceptance unverified), AM4 (acceptance unverified), AM6 (acceptance unverified)
Contract:
am_field_gateAcceptance: declared stair fixtures, measured climbs, descents, aborts and floor inspections; REFUSES on partial coverage
Authored effort: 2. Executor kind: Organ. Responsible, accountable and verifier not established. Inspect retained worklog.
Runtime observation: UNKNOWN; outcome UNKNOWN; observed epoch -1. Declared owner: . Receipt
, SHA-256. Identity-bound observation is not accepted completion. Qualification and deployment remain unverified by this projection.
Learning and practice paths
No structured learning path is declared for this plan. Existing research, roadmap and worklog remain available above.
Rung dossiers — every record that bears on a rung, in one place
nx_swcompare_evidence appliancemove writes it beside its stamp); every gate below reads UNRECORDED until it runs.knowledge/organ_gate.conf read from this working directory (1 rows) and from the estate root (196 rows); rows in both counted once: 0; declarations read: 197. Every declaration in either copy counts, so a stub beside the publisher can never hide the root.AM1 Stair-geometry envelope solver · cell WATCHING · gate NO-GATE-DECLARED
| Contract | am_stair_geom · executor Organ · 1 u · stands on nothing |
|---|---|
| Definition of done | OSHA 1910.25 riser and tread envelope as DATA rows [oshastairs]; solver derives module geometry; gate includes a neg-control stair outside the envelope that must REFUSE |
| Matrix cell | STAIRS: Powered ascent and descent with load · runtime/nx_applmove.nx · WATCHING decl |
| Gate | NO-GATE-DECLARED — knowledge/organ_gate.conf carries no row for nx_applmove; declare nx_applmove TAB <gate> and the ship loop proves it and the verdict lands here. |
| Work log | no log row names this rung yet |
AM2 Load and margin calculator · cell WATCHING · gate NO-GATE-DECLARED
| Contract | am_load_margin · executor Organ · 1 u · stands on nothing |
|---|---|
| Definition of done | BOM-derived axle, bearing and deck margins; gate refuses any margin under the declared floor; capacities graded beside the 1200 and 1,500 lb incumbents [escalera] [powermate] |
| Matrix cell | LOAD: Rated capacity in the appliance class (600 lb and up) · runtime/nx_applmove.nx · WATCHING decl |
| Gate | NO-GATE-DECLARED — knowledge/organ_gate.conf carries no row for nx_applmove; declare nx_applmove TAB <gate> and the ship loop proves it and the verdict lands here. |
| Work log | no log row names this rung yet |
AM3 CG tipover simulator · cell WATCHING · gate NO-GATE-DECLARED
| Contract | am_tipover_sim · executor Organ · 1 u · stands on AM1 |
|---|---|
| Definition of done | stair rake and load-height sweep; neg-control fixture MUST tip; verdict carries the margin number, never a bare pass |
| Matrix cell | STAIRS: Tipover stability margin, modeled not guessed · runtime/nx_applmove.nx · WATCHING decl |
| Gate | NO-GATE-DECLARED — knowledge/organ_gate.conf carries no row for nx_applmove; declare nx_applmove TAB <gate> and the ship loop proves it and the verdict lands here. |
| Work log | no log row names this rung yet |
AM4 Descent brake-energy model and lock spec · cell WATCHING · gate NO-GATE-DECLARED
| Contract | am_brake_energy · executor Organ · 1 u · stands on AM2 |
|---|---|
| Definition of done | worst-case descent energy vs brake rating with lock-on-release as the refusal rule [powermate] |
| Matrix cell | STAIRS: Automatic load lock on release (the safety bar) · runtime/nx_applmove.nx · WATCHING decl |
| Gate | NO-GATE-DECLARED — knowledge/organ_gate.conf carries no row for nx_applmove; declare nx_applmove TAB <gate> and the ship loop proves it and the verdict lands here. |
| Work log | no log row names this rung yet |
AM5 BOM, landed cost and sourcing verdict · cell NO-MATRIX-ROW · gate NO-MATRIX-ROW
| Contract | am_bom_cost · executor Organ · 2 u · stands on AM2 |
|---|---|
| Definition of done | every component priced through lc_calc corridors and sp_mix reshore path; buy-vs-build table regenerates from the organ output |
| Matrix cell | NO-MATRIX-ROW — no matrix row carries am_bom_cost; the ranker reads this rung as unmapped and no cell can flip for it. Add the row and the join completes on the next publish. |
| Gate | the gate join needs a matrix row: no organ is named for this rung |
| Work log | no log row names this rung yet |
AM6 Glide-base design pack · cell WATCHING · gate NO-GATE-DECLARED
| Contract | am_glide_base · executor Organ · 2 u · stands on AM2 |
|---|---|
| Definition of done | floor-pressure model vs flooring classes as DATA graded beside the air-film bar [airsled]; footprint fit rows for common appliances; printed-fixture lane via the slicer |
| Matrix cell | GLIDE: Move a heavy appliance across finished floors without damage · runtime/nx_applmove.nx · WATCHING decl |
| Gate | NO-GATE-DECLARED — knowledge/organ_gate.conf carries no row for nx_applmove; declare nx_applmove TAB <gate> and the ship loop proves it and the verdict lands here. |
| Work log | no log row names this rung yet |
AM7 Field-trial gate · cell WATCHING · gate NO-GATE-DECLARED
| Contract | am_field_gate · executor Organ · 2 u · stands on AM3, AM4, AM6 |
|---|---|
| Definition of done | declared stair fixtures, measured climbs, descents, aborts and floor inspections; REFUSES on partial coverage |
| Matrix cell | FIELD: Instrumented field-trial protocol on real stairs · runtime/nx_applmove.nx · WATCHING decl |
| Gate | NO-GATE-DECLARED — knowledge/organ_gate.conf carries no row for nx_applmove; declare nx_applmove TAB <gate> and the ship loop proves it and the verdict lands here. |
| Work log | no log row names this rung yet |
dossiers=7 cells_joined=6 no_matrix_row=1 (sum 7) gates_recorded=0 gates_unrecorded=0 no_gate_declared=6 (sum 6 of cells_joined) evgates=UNSTAMPED
Capability comparisons
Compare the field, search individual capabilities and open their source and adoption evidence. Documented presence does not establish comparative quality.
Position map — centrality and distinctiveness
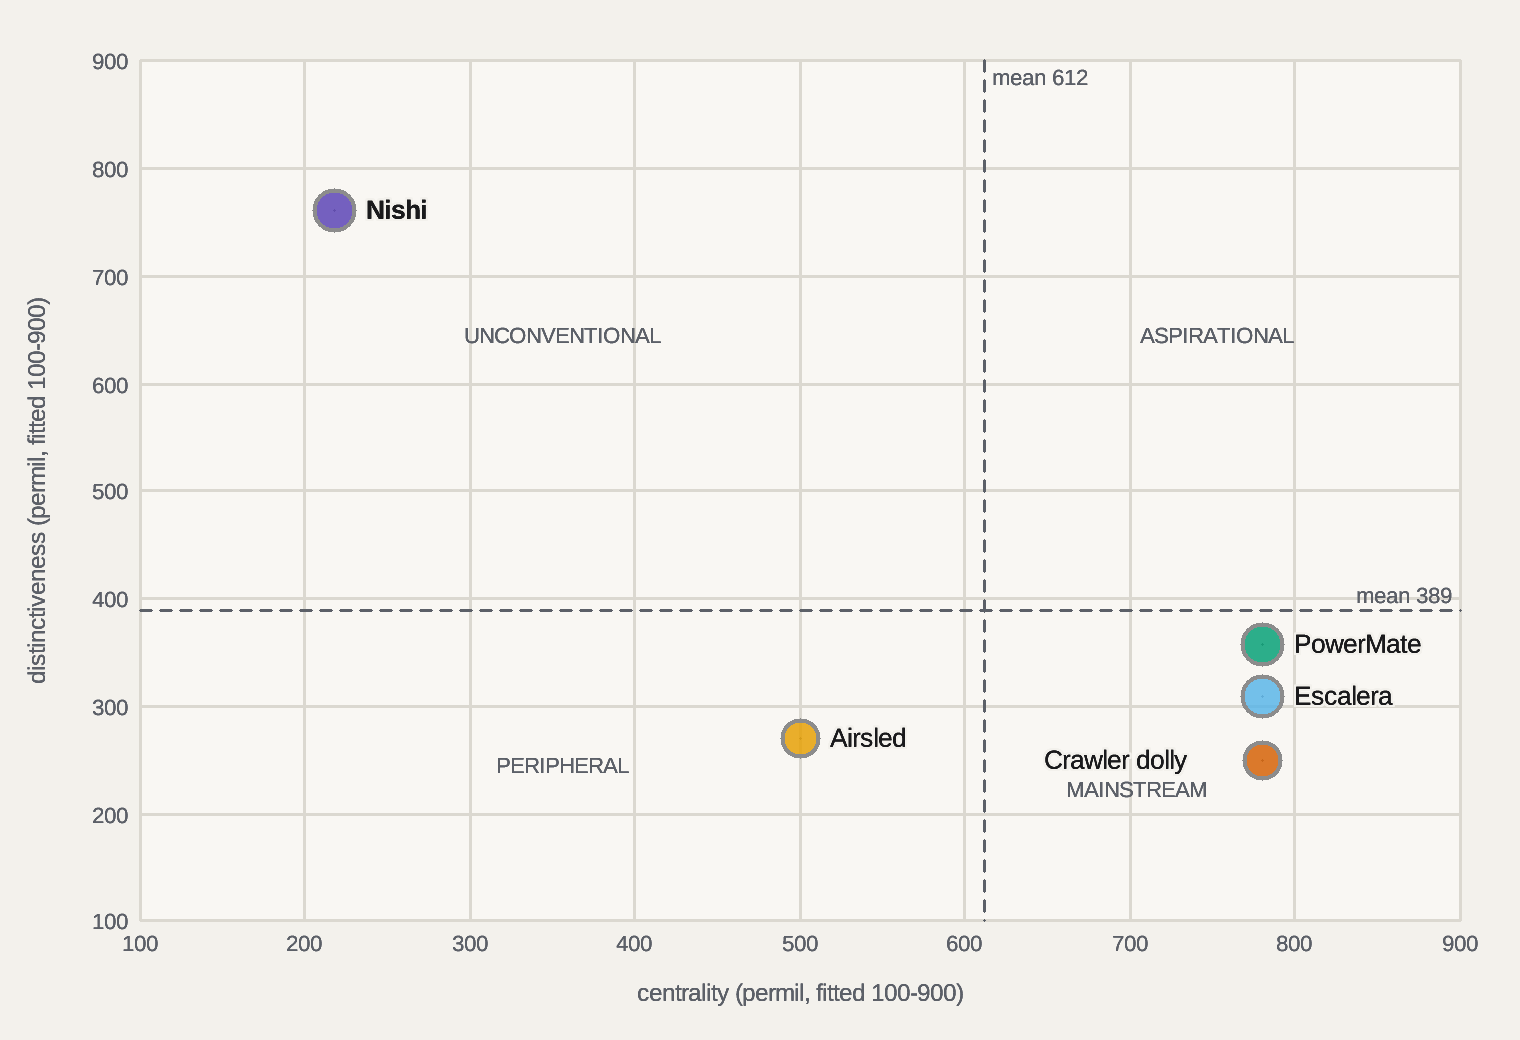
The four-quadrant map the field uses for brand strategy (Dawar and Bagga, HBR June 2015), re-derived from this matrix on every publish. Centrality is the share of the category's feature mass a player covers, each feature weighted by how many hold it; distinctiveness is the average lead over each rival on the rows the player holds; breadth is the depth-weighted share of the whole matrix (the bubble); depth is how deeply the rows held are held; momentum is the day-over-day move off the spine (green rising, red falling, grey until day two); the dashed path runs first day → previous day → today. Dividers are the category means. Axes are fitted to the field of play, so read the tick numerals, not the frame. Rival marks are documented presence, so a rival's position reads the record, never its quality. The picture grades its own readability below; the table beside it is the same data for a screen reader or a second method.
knowledge/compare/appliancemove.cdmap (cut|x|y, cube|x|y|z); absent = the HBR defaultsbubble area = breadth · ring = momentum (green rising, red falling, grey until day two) · dashed = category means · axes fitted to the field of play: centrality 100–900, distinctiveness 100–900 of 0–1000 permil (the full range put every player in one corner)
readability of the 2D cut, self-graded by the layout ruler: label overlaps 0 · labels over marks 0 · off-canvas 0 · unresolved labels 0 · mark overlaps 0 (a fact of the data: two players that close are that close) · data spread 671 permil of the plot · quadrant words unseated 0
text contrast, measured with wcag2-ratio (floors from contrast.conf), light theme: labels 16.24 (floor 4.50) · notes 16.24 (floor 4.50) · quadrant words 5.89 (floor 4.50) · tick numerals 5.89 (floor 4.50) · axis titles 5.59 (floor 4.50) · dark theme: labels 13.78 (floor 4.50) · quadrant words 5.55 (floor 4.50) · axis titles 5.97 (floor 4.50) · dark classes under their floor 0 (one figure serves both themes: a dark shortfall is a token to fix, never a class to hide) · classes refused under their floor 0 (a refused class is not drawn; the scale classes are measured, never hidden) · export: SVG PNG (receipt, rendered by the estate's own rasteriser from this page)

readability of the 3D cube, self-graded by the layout ruler: label overlaps 0 · labels over marks 0 · off-canvas 1 · unresolved labels 0 · mark overlaps 1 (a fact of the data: two players that close are that close) · data spread 458 permil of the plot
10 panels over 5 registered axes, every pair once (the lower axis on x, the higher on y) · each panel fitted to its own field of play, first and last tick numerals shown · no labels in a small cut, the legend names the colours; the grade below reports the mark terms only (MM summed over the panels, spread averaged)
readability of the small multiples, self-graded by the layout ruler: label overlaps 0 · labels over marks 0 · off-canvas 0 · unresolved labels 0 · mark overlaps 10 (a fact of the data: two players that close are that close) · data spread 523 permil of the plot
| Player | Quadrant | centrality | distinctiveness | breadth | depth | momentum | Rows held | Days on spine | First seen |
|---|---|---|---|---|---|---|---|---|---|
| Nishi | Unconventional | 218 | 761 | 355 | 761 | 0 since 2026-09-23 | 7 | 10 | 2026-09-15 |
| Airsled | Peripheral | 500 | 270 | 200 | 750 | 0 since 2026-09-23 | 4 | 10 | 2026-09-15 |
| Escalera | Mainstream | 781 | 309 | 355 | 761 | 0 since 2026-09-23 | 7 | 10 | 2026-09-15 |
| PowerMate | Mainstream | 781 | 357 | 377 | 809 | 0 since 2026-09-23 | 7 | 10 | 2026-09-15 |
| Crawler dolly | Mainstream | 781 | 250 | 311 | 666 | 0 since 2026-09-23 | 7 | 10 | 2026-09-15 |
| Day | Matrix rows reviewed | Players recorded |
|---|---|---|
| 2026-09-15 | 15 | 5 |
| 2026-09-16 | 15 | 5 |
| 2026-09-17 | 15 | 5 |
| 2026-09-18 | 15 | 5 |
| 2026-09-19 | 15 | 5 |
| 2026-09-20 | 15 | 5 |
| 2026-09-21 | 15 | 5 |
| 2026-09-22 | 15 | 5 |
| 2026-09-23 | 15 | 5 |
| 2026-10-08 | 15 | 5 |
players 5|matrix rows 15|feature mass 32|centrality mean 612|distinctiveness mean 389|axes 5|spine days 10 (shown 10)|rows written today 0|readability defects 2D 0 cube 1|spine knowledge/status/cdmap/appliancemove.spine
Capability matrix — measured against source
◉ authored stronger claim; source present● present◐ partial○ absent? unassessed; excluded from relative comparison · click any capability for its evidence
Peer cell coverage: authored assessed 60, unassessed 0. Authored assessments are not verified outcomes.
No capabilities match this filter or search.
| Capability | Nishi | Airsled | Escalera | PowerMate | Crawler dolly |
|---|---|---|---|---|---|
| GLIDE | |||||
Move a heavy appliance across finished floors without damageOpen — watchingruntime/nx_applmove.nx : am_glide_base, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. Airsled floats the load on an air film so finished floors never see a wheel [airsled]; climbers and crawlers roll on wheels or tracks and protect floors only as well as their tread. Contract = the glide-base design organ: wheel material, footprint pressure and floor-damage model as DATA rows, proven by a floor-pressure gatePros none measured yetCons behind Airsled (leads), Escalera, PowerMate, Crawler dolly; open contract; expected source declaration not established | ○ | ◉ | ● | ● | ● |
Permanent under-appliance install (a retrofit base that stays)Open — watchingruntime/nx_applmove.nx : am_base_fit, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. No incumbent in this field stays under the appliance -- movers arrive, move and leave; adjustable roller bases exist as a commodity adjacent market but do not climb. Contract = a base that fits common appliance footprints as DATA (width, depth, load), glides on demand and locks solid otherwisePros none measured yetCons open contract; expected source declaration not established | ○ | ○ | ○ | ○ | ○ |
| STAIRS | |||||
Powered ascent and descent with loadOpen — watchingruntime/nx_applmove.nx : am_stair_geom, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. Escalera and PowerMate own this format at 1200 and 1,500 lb ratings [escalera] [powermate]; crawlers do it at consumer price in the 330 lb class [crawler]. Contract = the stair-geometry envelope solver: riser and tread limits read from the published envelope [oshastairs] as DATA, module geometry derived from itPros none measured yetCons behind Escalera (leads), PowerMate (leads), Crawler dolly (leads); open contract; expected source declaration not established | ○ | ○ | ◉ | ◉ | ◉ |
Automatic load lock on release (the safety bar)Open — watchingruntime/nx_applmove.nx : am_brake_energy, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. The PowerMate braking behaviour locks the load in place the moment the operator releases the controls [powermate] -- the field safety bar. Contract = the descent brake-energy model and lock spec, proven by a gate that refuses any design whose worst-case descent energy exceeds the brake ratingPros none measured yetCons behind Escalera, PowerMate (leads), Crawler dolly; open contract; expected source declaration not established | ○ | ○ | ● | ◉ | ● |
Tipover stability margin, modeled not guessedOpen — watchingruntime/nx_applmove.nx : am_tipover_sim, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. Incumbents publish capacities, not stability envelopes. Contract = the CG-tipover simulator over stair rake, load height and operator input, with a neg-control fixture that MUST tip rival marks uncited — the Yes, Best or Part codes on this row are an observation read with no reference mark behind themPros none measured yetCons behind Escalera, PowerMate, Crawler dolly; open contract; expected source declaration not established | ○ | ○ | ● | ● | ● |
| LOAD | |||||
Rated capacity in the appliance class (600 lb and up)Open — watchingruntime/nx_applmove.nx : am_load_margin, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. Escalera rates 1200 lb [escalera], PowerMate 1,500 lb [powermate], the Liftkar line covers the mid-range [liftkar], crawler dollies start near 330 lb [crawler]. Contract = the load and margin calculator: axle, bearing, deck and weld margins derived from the BOM as DATAPros none measured yetCons behind Airsled, Escalera (leads), PowerMate (leads), Crawler dolly; open contract; expected source declaration not established | ○ | ● | ◉ | ◉ | ◐ |
Single-operator useOpen — watchingruntime/nx_applmove.nx : am_solo_op, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. Every incumbent format is single-operator by design; ours must be too or it loses the house call rival marks uncited — the Yes, Best or Part codes on this row are an observation read with no reference mark behind themPros none measured yetCons behind Airsled, Escalera, PowerMate, Crawler dolly; open contract; expected source declaration not established | ○ | ● | ● | ● | ● |
| DESIGN | |||||
Outcome-to-capability decomposition (name the product, derive the gaps)Source present; authored stronger claim:pd_parse in runtime/_hdl_build/nx_product_decompose.nx, verified at emit. The estate product decomposer maps a named outcome onto required capabilities and unproven-opportunity gaps over the design-to-market planes -- no incumbent ships its analysis lane Adoption: REGISTERED-DARK — PARTIAL: callable, authorised, completed MCP invocation not established by supplied journal window; lifetime history unknown (direct execution may be recorded elsewhere; this scan does not establish lifetime use); no execution surface runs it either (clock, cron, daemon, roster, actlog and surfaced forks checked).Pros Source symbol found; stronger capability claim is authored; ahead of Airsled, Escalera, PowerMate, Crawler dollyCons not adopted yet: callable, authorised, completed MCP invocation not established by supplied journal window; lifetime history unknown (direct execution may be recorded elsewhere; this scan does not establish lifetime use); no execution surface runs it either (clock, cron, daemon, roster, actlog and surfaced forks checked) | ◉ | ○ | ○ | ○ | ○ |
Digital-twin fabrication lane (STL to G-code, printed fixtures)Source present; authored stronger claim:sl_slice_stl in runtime/_hdl_build/nx_slicer_lib.nx, verified at emit. The sovereign slicer emits G-code from STL for printed prototype fixtures -- the prototype lane runs on the estate fabrication substrate, not a vendor toolchain Adoption: LIB-WIRED importers=2 nonval=1 — fully adopted (top of its ladder).Pros Source symbol found; stronger capability claim is authored; ahead of Airsled, Escalera, PowerMate, Crawler dolly; fully adopted on the estate ladderCons none on the measured axes (rival marks are documented presence, not depth) | ◉ | ○ | ○ | ○ | ○ |
| BUSINESS | |||||
Landed-cost and tariff corridor pricing for the BOMMeasured:lc_calc exists in runtime/_hdl_build/nx_landed_cost.nx, verified at emit. Every imported component priced through the sovereign landed-cost engine (duties, MPF, HMF, corridor ranking) before it enters the BOM Adoption: RUN-BY:clock — fully adopted (top of its ladder).Pros Implementing source symbol found; runtime acceptance separate; ahead of Airsled, Escalera, PowerMate, Crawler dolly; fully adopted on the estate ladderCons none on the measured axes (rival marks are documented presence, not depth) | ● | ○ | ○ | ○ | ○ |
Sourcing-mix and reshore-path pricingMeasured:sp_mix exists in runtime/_hdl_build/nx_sourcing_path.nx, verified at emit. The sourcing-mix pricer walks the path from import-heavy to domestic BOM step by step with incentives as data -- the buy-vs-build and where-to-build instrument Adoption: REGISTERED-DARK — PARTIAL: callable, authorised, completed MCP invocation not established by supplied journal window; lifetime history unknown (direct execution may be recorded elsewhere; this scan does not establish lifetime use); no execution surface runs it either (clock, cron, daemon, roster, actlog and surfaced forks checked).Pros Implementing source symbol found; runtime acceptance separate; ahead of Airsled, Escalera, PowerMate, Crawler dollyCons not adopted yet: callable, authorised, completed MCP invocation not established by supplied journal window; lifetime history unknown (direct execution may be recorded elsewhere; this scan does not establish lifetime use); no execution surface runs it either (clock, cron, daemon, roster, actlog and surfaced forks checked) | ● | ○ | ○ | ○ | ○ |
Domestic supply-chain and good-jobs case for the manufacturing decisionMeasured:sc_domestic_permil exists in runtime/_hdl_build/nx_supplychain_case.nx, verified at emit. Origin class, energy risk, single-source and value roll into weighted risk and domestic-content permil -- the government-facing case a domestic build leads with Adoption: LIB-WIRED importers=3 nonval=2 — fully adopted (top of its ladder).Pros Implementing source symbol found; runtime acceptance separate; ahead of Airsled, Escalera, PowerMate, Crawler dolly; fully adopted on the estate ladderCons none on the measured axes (rival marks are documented presence, not depth) | ● | ○ | ○ | ○ | ○ |
Go-to-market channel engine (facade live in an adjacent domain)Measured:gtm_channel_best exists in runtime/nx_gtm_svc.nx, verified at emit. The GTM facade ranks channels per product today in the supplement domain -- mover, dealer and property-manager channel rows are a data admission, not new code Adoption: REGISTERED-DARK — PARTIAL: callable, authorised, completed MCP invocation not established by supplied journal window; lifetime history unknown (direct execution may be recorded elsewhere; this scan does not establish lifetime use); no execution surface runs it either (clock, cron, daemon, roster, actlog and surfaced forks checked).Pros Implementing source symbol found; runtime acceptance separate; ahead of Airsled, Escalera, PowerMate, Crawler dollyCons not adopted yet: callable, authorised, completed MCP invocation not established by supplied journal window; lifetime history unknown (direct execution may be recorded elsewhere; this scan does not establish lifetime use); no execution surface runs it either (clock, cron, daemon, roster, actlog and surfaced forks checked) | ● | ○ | ○ | ○ | ○ |
| EVIDENCE | |||||
Sovereign mirrored and pinned reference register for this fieldMeasured:knowledge/fetched/cmp_appliancemove exists in knowledge/compare/appliancemove.refs, verified at emit. Every rival claim on this page resolves to a mirror in the estate evidence store, content-pinned by hash and re-measured on every emit -- no incumbent publishes its evidence chain Adoption: ABSENT — PARTIAL: no source and no binary: this is a build contract, not a partial deploy.Pros Implementing source symbol found; runtime acceptance separate; ahead of Airsled, Escalera, PowerMate, Crawler dollyCons not adopted yet: no source and no binary: this is a build contract, not a partial deploy | ● | ○ | ○ | ○ | ○ |
| FIELD | |||||
Instrumented field-trial protocol on real stairsOpen — watchingruntime/nx_applmove.nx : am_field_gate, re-measured on every compare beat. Ship that symbol and this mark flips itself; the comparewatch- plane row flips with it. Incumbents are proven products; ours is unproven until a field gate exists. Contract = the trial-protocol gate: measured climbs, descents, aborts and floor inspections on declared fixtures, REFUSING to pass on partial coverage rival marks uncited — the Yes, Best or Part codes on this row are an observation read with no reference mark behind themPros none measured yetCons behind Airsled, Escalera, PowerMate, Crawler dolly; open contract; expected source declaration not established | ○ | ● | ● | ● | ● |
| Class | Count | Note |
|---|---|---|
| rows with rival marks | 7 | rows carrying a Yes, Best or Part in a rival column |
| cited | 4 | a reference mark resolves to a pinned mirror |
| uncited | 3 | an observation read, badged until a reference lands |
| rows, summed | 7 | RECONCILED: the parts sum to the total 7 |
Delivery and evidence
Inspect risks, technical debt, rendered observations, experiments and references. Read scope and limitations alongside every result.
Risk register
| Risk | Likelihood x impact | Mitigation |
|---|---|---|
| Stairs plus heavy loads is an injury domain -- a design error is a person crushed | possible x severe | never-ship-without-gate: AM4 lock-on-release refusal, AM3 tipover neg-control, AM7 field gate with abort coverage; no article ships on partial gate coverage |
| A watch contract flips on symbol existence, so a stub reads green | possible x high | the flip is the receipt, the rung gate is the proof -- every rung pre-declares its refusal rule |
| The wedge is real but the unit economics are not | possible x medium | M1 gates hardware spend on the measured BOM verdict; the biz rows regenerate from the costing organs, never from seat optimism |
Debt register
| Id | Sev | What it is | Unblock |
|---|---|---|---|
| am-crawler-teardownnot in this scope | 3 | No teardown unit in hand -- the crawler BOM baseline is unpriced | buy one 330 lb-class crawler unit [crawler]; AM5 prices its BOM as the reference article |
Person · product · place — not yet measured for this domain
knowledge/compare/appliancemove.ppp (rows surface|nishi or c1..c4|label|url|connect naming OUR live surface and each rival's front door), run nx_ppp_probe domain appliancemove, and this section fills itself on the next beat: the same ruler on both sides — privacy and CX (third-party hosts, tracker classes, cookies, security headers), design and longevity (design hygiene, computed WCAG contrast, render-blocking resources, unsized media, script weight, theme and motion queries), findability (landmarks, skip link, on-site search, breadcrumb, headings, internal links).The field — discovered, not chosen
Rows written by nx_field_discover from appliancemove.seeds: the industry's own lists (Wikipedia wikitext, GitHub topics, awesome lists) read mechanically, every candidate counted across seeds. The matrix columns above are a SEAT'S pick; this band is the population they were picked from, and the stats line measures one against the other. A rival here is a lead, never a verdict — it earns a column when its capabilities are read and pinned.
| Class | Count | Note |
|---|---|---|
| seeds | 3 | |
| scanned | 3 | |
| fetched | 3 | |
| reused | 0 | |
| failed | 0 | |
| named | 3 | |
| candidates | 3 | |
| mentions | 3 | |
| capped | 0 |
| Rank | Rival | Seeds | Mentions | First seed | Kind | Link |
|---|---|---|---|---|---|---|
| 1 | Airsled | 1 | 1 | col0-airsled | named | https://airsled.com/how-it-works/benefits/ |
| 2 | Escalera | 1 | 1 | col1-escalera | named | https://handtrucks2go.com/Escalera-StairCat-Stair-Climbing-Hand-Trucks-Stair-Climbing-Forklifts.html |
| 3 | Crawler dolly | 1 | 1 | col3-crawler | named | https://ozrobotics.com/shop/crawler-electric-stair-climber-dolly-330-lb-capacity-stair-climbing-hand-truck-cart-ct150pb/ |
field candidates 3|shown 3 of 3|matrix columns in the field 3 of 4|discovered rivals with no column 0|malformed rows 0 (counted, never rendered)|read-capped 0
Exclusive and shared capabilities
This board grades 15 capabilities: 9 exclusive to it and 6 shared with other boards. Shared rows on this page: 6 = home here 0 + home elsewhere 1 + ambiguous 0 + undecided 5 + refused 0 (partition 6); undecided = unmapped 2 + unproven 3 + unevidenced 0; homonyms 0; since the previous census: new 0, resolved 0. Census FRESH age_s=6679.
| Capability | Organ | Boards grading it | Home | Rule | Evidence | Standing on this board |
|---|---|---|---|---|---|---|
| lc_calc | nx_landed_cost.nx | growth*, appliancemove, braketool, soilscience, alignbiz, carflip, butterchurn, phototwin, tradecompliance | growth | rung | plan | home elsewhere adopt: @xrow growth|lc_calc|home by rung (fleet duplicate census) |
| pd_parse | nx_product_decompose.nx | appliancemove, braketool, soilscience, alignbiz, realestate, supimacotton, butterchurn, phototwin | — | none | unproven | undecided |
| sl_slice_stl | nx_slicer_lib.nx | appliancemove, braketool, butterchurn | — | none | unmapped | undecided |
| sp_mix | nx_sourcing_path.nx | appliancemove, braketool, supimacotton | — | none | unmapped | undecided |
| sc_domestic_permil | nx_supplychain_case.nx | appliancemove, braketool, realestate | — | none | unproven | undecided |
| gtm_channel_best | nx_gtm_svc.nx | appliancemove, braketool, soilscience, alignbiz, carflip, supimacotton, butterchurn, phototwin | — | none | unproven | undecided |
Gaps from the record — what the estate does that no board carries
The record census (nx_goalmap record) reads the invoked-tool population and every plan queue row and files each organ or directive that NO matrix, plan or gates row names. A row here is a callout the boards missed: adjudicate it onto a board or declare it infrastructure. Census state STALE (age 1395784 s), sources read 4 of 7 declared — a BLIND census is a FLOOR: unread sources can only add rows.
| kind | name | board | source | evidence |
|---|
rows shown 0|this board's directives 0|estate-wide un-boarded organs 452 (listed in full on /compare/ecosystem)|census rows 639|malformed 0 (counted, never rendered)
References
- [airsled] Airsled. How it works -- benefits of air-film load movement. Airsled vendor page -- a micro-thin air cushion under the load cuts the force needed to move it to roughly 1 percent of load weight; floor-safe movement of appliances and equipment. publisher · read in our library
knowledge/fetched/cmp_appliancemove_airsled.html· pinhf7d856640e44cc7769d5ea548a36ed05f052b0ae4f395449cabecd5c7840aa91· accessed 2026-08-19 · vendor-docGrounds: The GLIDE rows and the Airsled column: the incumbent floor-safe glide format the permanent base must match on finished floors. - [escalera] Handtrucks2go. Escalera StairCat stair-climbing hand trucks and forklifts. Dealer catalog page -- tempered-aluminum StairCat line with capacities to 1200 lb, winch-lift variants. publisher · read in our library
knowledge/fetched/cmp_appliancemove_escalera.html· pinh96a461d75d465cb4a5894dd9e4fc11b80404dc73dce4df6885f40e83131fb4fd· accessed 2026-08-19 · vendor-docGrounds: The STAIRS powered ascent row and the LOAD capacity row: the professional climber bar at 1200 lb. - [powermate] Handtrucks2go safety blog. Best electric stair-climbing hand truck -- expert comparison (2025, read Aug-2026) -- PowerMate M-1 class at 1,500 lb capacity with a fully automatic braking system that locks the load when the operator releases the controls. publisher · read in our library
knowledge/fetched/cmp_appliancemove_powermate.html· pinh941a31bc1655f38876f1a45c3e5842d8f67b2d6caee038161a5b21706ea595cc· accessed 2026-08-19 · mirrored-indexGrounds: The STAIRS load-lock safety row and the LOAD capacity row: lock-on-release is the field safety bar our brake-energy contract adopts as a refusal rule. - [crawler] OzRobotics. Crawler electric stair-climber dolly CT150 -- 330 lb capacity, 400W motor, lithium battery, rubber caterpillar track drive. Vendor product page. publisher · read in our library
knowledge/fetched/cmp_appliancemove_crawler.html· pinh7992bac018aa54b290b6de6cec49c773b667f52d526a2a5d2a98cedb43052e4b· accessed 2026-08-19 · vendor-docGrounds: The consumer-price crawler column and the teardown-unit row of the plan: the 330 lb tracked class that automates the climb cheaply. - [oshastairs] OSHA. 29 CFR 1910.25 -- Stairways (general industry). Official regulation text -- standard stairs: maximum riser height 9.5 inches and minimum tread depth 9.5 inches, the published geometry envelope. publisher · read in our library
knowledge/fetched/cmp_appliancemove_oshastairs.html· pinhede634ef50186cbb3c59c656a9c84babeef4b65f5c7e36e815941cd57ca5925d· accessed 2026-08-19 · published-standardGrounds: The stair-geometry envelope row and rung AM1: the solver reads this envelope as DATA rather than guessing stair dimensions. - [liftkar] Handtrucks2go. Magliner SAL Ergo Liftkar electric stair-climbing hand truck. Dealer catalog page -- the ergonomic mid-range powered climber line. publisher · read in our library
knowledge/fetched/cmp_appliancemove_liftkar.html· pinhc61176d5d0b01e74ab1245fa6d0ca4a85b0afc18c88581c63157aadc14932844· accessed 2026-08-19 · vendor-docGrounds: The LOAD capacity row mid-range and the go-to-market biz row: the rental and house-call channel shape of the incumbent climbers.
generated by nx_swcompare_matrix (sovereign NishiLang organ) from knowledge/compare/appliancemove.matrix · source checks show implementation presence; runtime and user-outcome evidence are reported separately · JavaScript supports page controls